AU

Mechatronics Engineer, R&D at Unifiller

Alex Uamai

I build new machines for food production, and more and more of them are robots.

My work starts as a blank SolidWorks file and ends on a factory floor, with mechanics, electronics and code all pulling their weight. Robots that handle real, messy, physical work are what I'm chasing next, starting with a master's in robotics at Johns Hopkins.

Miss once, never twice.

The rule I build by. Getting better at anything comes down to showing up for the reps: in the gym, at the bench, in front of a blank SolidWorks file. A missed day happens. Two in a row is how a habit quietly dies. So I give myself one slip, and I don't take a second.

01

Research

In progress · Iyan · started Oct 2026

Can I teach a robot to make food from video while incorporating uncertainties like poundo’s properties, all without a force sensor, for a simpler product?

A mound of pounded yam (iyan) on a white plate, served beside a plate of red stew and egusi soup with greens
Pounded yam with egusi soup
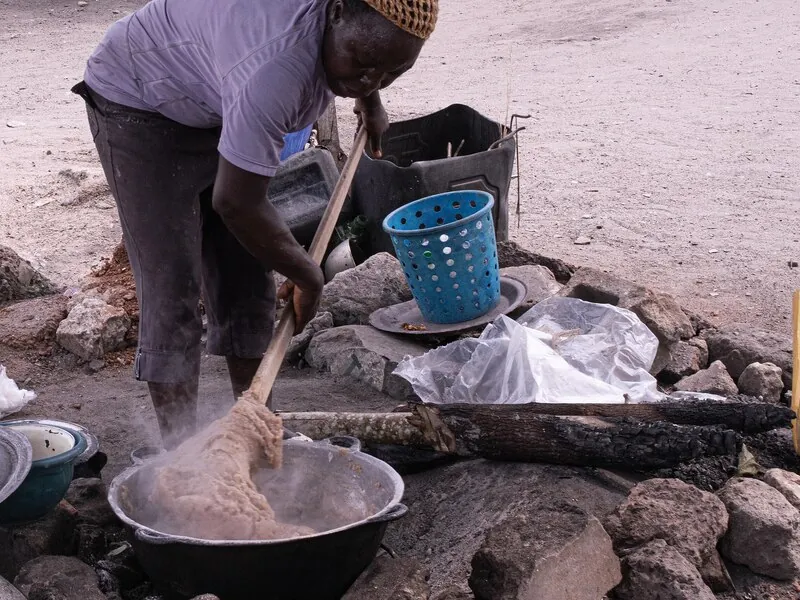
A woman turning a steaming yam-flour dough in a pot over a fire with a long wooden stick
Made today: yam flour, turned with a stick

First, what’s poundo?

Pounded yam is a smooth, stretchy West African staple, eaten with soups like egusi. It used to be pounded by hand in a mortar. Today most people make poundo from yam flour: stirred into hot water, then turned hard with a wooden stick until smooth.

That turning is hot, heavy, repetitive work. That’s why I’m teaching a robot to do it.

Photos: Toludpilgrim, CC BY-SA 3.0; Koutchika Lihouenou Gaspard (amala, a yam-flour swallow), CC BY-SA 4.0, cropped; via Wikimedia Commons.

  1. 01

    Learn from video

    The motion comes from clips of people turning poundo. The stick-tip path is tracked and retargeted to a robot arm.

  2. 02

    Handle uncertainty

    The dough goes from loose flour and water to a thick, sticky mass, and no two pots behave the same. The robot has to adapt as the resistance changes.

  3. 03

    No force sensor

    The robot that runs has none. A load-cell stick is used only in training, to measure what a real turn takes.

Read the case study
02

Projects

Franka Research 3 robot arm in a posed configuration in the MuJoCo simulator

In progress · Solo · Research

Iyan

A robot arm learning to turn poundo yam, a West African staple, from videos of people making it. So far: IK, PD control and contact sensing in simulation, now on a Franka Research 3. Next: learning the turning motion from video.

  • MuJoCo
  • LeRobot
  • Franka FR3
  • Jacobian IK
  • Contact sensing
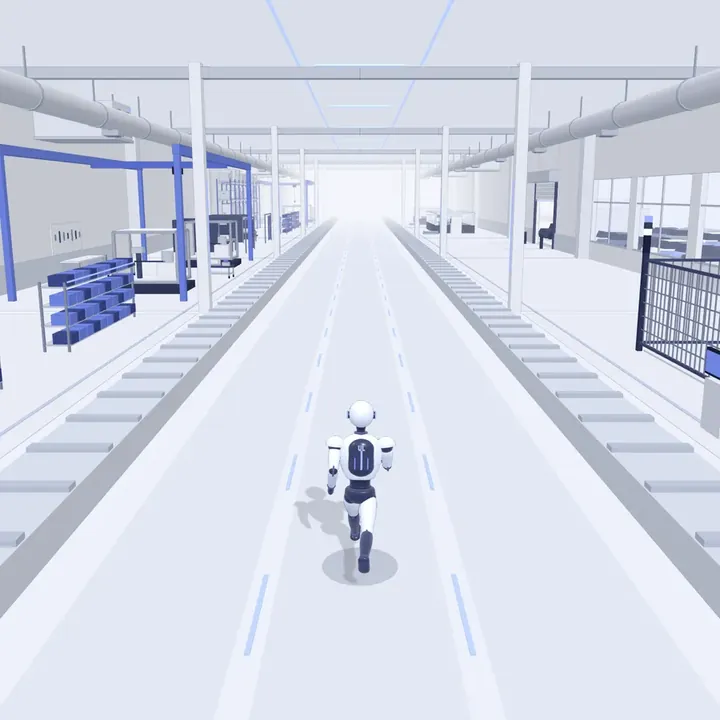
UL-H1 humanoid running down a car-plant floor in Servo Sprint

Solo · Shipped

Servo Sprint & auamai.dev

A 3D robot runner in three.js with a Cloudflare Workers + D1 leaderboard, shipped by running AI coding agents like a dev team: specs, build reviews, versioned releases. I rebuilt auamai.dev from scratch around it.

  • three.js
  • Cloudflare Workers
  • D1
  • AI coding agents
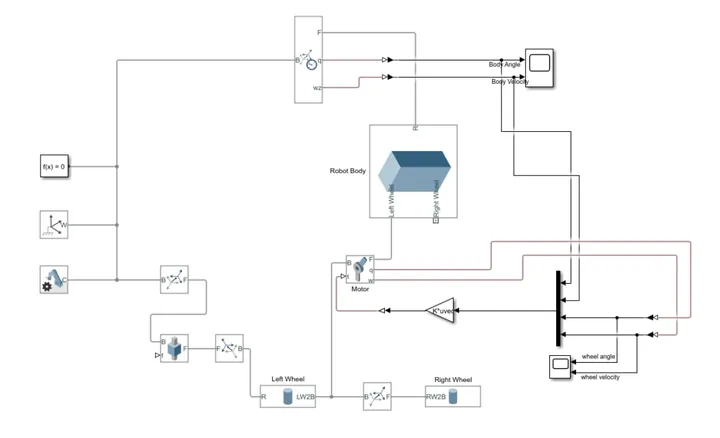
Simscape model of a two-wheel self-balancing robot

Course project · Modern control

Two-wheel self-balancing robot

Stable balance in simulation from a state-space controller I designed. Modelled the dynamics in MATLAB and Simulink, checked controllability and observability, then built a 3D Simscape model.

  • MATLAB
  • Simulink
  • Simscape
  • State-space control
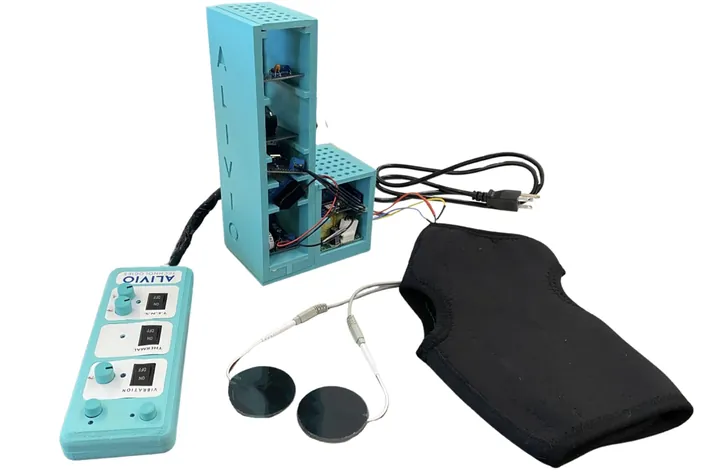
Lief foot wearable prototype for dystonia

SFU capstone · Controls lead

Lief: foot wearable for dystonia pain

A foot wrap that eases dystonia pain with PWM-controlled vibration. I led controls: firmware for two coin vibration motors, the protoboard circuit, and a desktop GUI for tracking sessions.

  • C
  • Arduino
  • Python
  • PySide
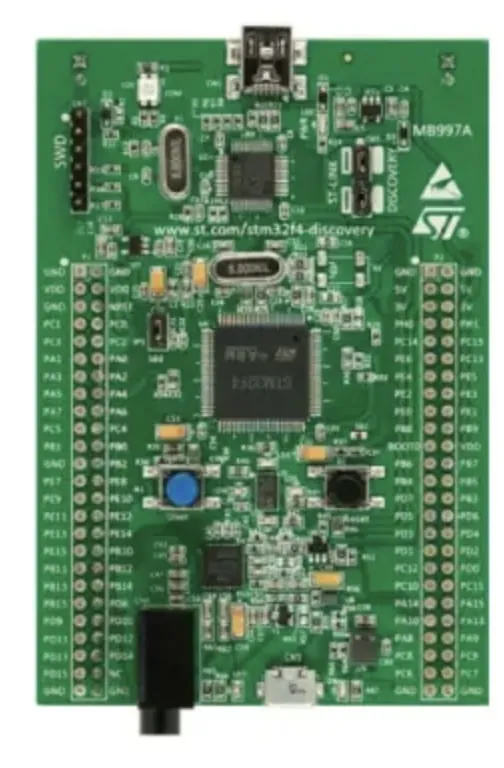
STM32F407 Discovery board used as a motion game controller

SFU coursework · Embedded

Tilt game controller on STM32

Tilt the board to steer a Python 2D shooter. I wrote the SPI driver for its accelerometer and used timers and interrupts to stream motion over USB.

  • STM32F407
  • C
  • SPI
  • Interrupts

SFU coursework · Hardware

BLE embedded controller

A Bluetooth Low Energy control board, designed, brought up and debugged with a SEGGER J-Link, Tag-Connect and Code Composer Studio.

  • BLE
  • PCB
  • Firmware

SFU coursework · Embedded

DC motor controller

PWM motor control with encoder feedback and embedded firmware on an 8051 platform.

  • 8051
  • PWM
  • Encoders
03

Experience

  1. Unifiller Systems

    Dec 2025 — Present

    Mechatronics Engineering Project Leader, R&D

    • Own the mechanical design of an industrial robotic food-automation platform, concept to production
    • Design end-effectors, precision assemblies and fixtures in SolidWorks with GD&T and tolerance analysis
    • Validate every design with FEA and first-principles checks before it's built
    • Integrate motion systems, sensors, pneumatics and embedded electronics into one platform
    • Drive DFM/DFA, sourcing, drawings, BOMs and change control to manufacturing readiness
  2. Grubchain

    May — Dec 2025

    Founder & CEO

    • Founded the company and grew the team from just me to 12
    • Led the team building a blockchain payment product
    • Talked blockchain and accountability on Channels Television and wrote an op-ed for the Vancouver Tech Journal
  3. Bethel Systems

    Dec 2024 — Dec 2025

    Technical & Business Analyst

    • Turned early-stage client product ideas into engineering development plans
    • Supported patent applications with technical concept work
  4. VMAC Air

    Sep — Dec 2021

    Mechanical Engineering Intern

    • Designed manufacturing fixtures and production test equipment in SolidWorks
    • Supported engineering and manufacturing improvement projects
  5. Ziva Dynamics

    May — Aug 2021

    Software Developer Intern

    • Shipped production C++ and Python tools with a Qt/PySide2 interface
    • Contributed to Git-based automated testing workflows
  6. Mulgrave School

    Jan — May 2021

    IT Intern

    • Built a Raspberry Pi remote 3D-printing system
    • Administered Windows Active Directory
04

Education

  1. Johns Hopkins University

    Starts Spring 2027

    M.S., Robotics and Autonomous Systems Engineering

    • Admitted to the Engineering for Professionals program, starting Spring 2027
    • Studying part-time while leading projects in R&D at Unifiller
  2. Simon Fraser University

    2018 — 2023

    B.A.Sc., Mechatronic Systems Engineering

    • Capstone: Lief, a foot wearable for dystonia pain, as controls lead
    • Built state-space controllers, STM32 and 8051 firmware, and BLE hardware along the way
05

Media

A couple of times someone handed me a mic. Here's what I said.

06

Skills

Robotics & simulation Now learning

  • MuJoCo
  • LeRobot
  • Franka FR3
  • Jacobian IK
  • PD & gravity compensation
  • Contact & force sensing
  • PyTorch
  • UR5e model

Mechanical

  • SolidWorks
  • GD&T
  • Tolerance analysis
  • FEA
  • DFM / DFA
  • Drawings & BOMs
  • Rapid prototyping

Electromechanical

  • Industrial robotics
  • Stäubli robots
  • Motion control
  • End-effectors
  • Actuators & sensors
  • Pneumatics
  • Embedded systems
  • PCB integration

Software & tools

  • Python
  • C++
  • C
  • VAL3
  • MATLAB / Simulink
  • Qt
  • Git
  • Linux
  • Jenkins
  • Jira
  • Linear
07

Building something with moving parts?

I'm always up for talking robotics, mechanical design, or hardware that has to work on a factory floor. Book 30 minutes on Meet, weekday evenings or weekend days, Pacific time.